Description
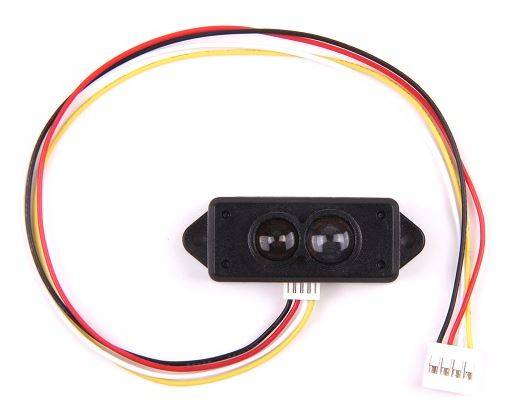
Grove TF Mini LiDAR Micro Single Point Laser Radar Ranging Module
Product Version
Grove-TF Mini LiDAR V1.0
Specification
|
Operating range
|
0.3m-12m
|
|
Maximum operating range at 10% reflectivity
|
5m
|
|
Average power consumption
|
0.6W
|
|
Applicable voltage range
|
4.5V-6V
|
|
Acceptance angle
|
2.3°
|
|
Minimum resolution ratio
|
1cm
|
|
Frequency
|
100Hz
|
|
Accuracy
|
1% (less than 6m), 2% (6m-12m)
|
|
Distance detection unit
|
cm
|
|
Wavelength
|
850nm
|
|
Size
|
42mm×15mm×16mm
|
|
Operating temperature
|
-20℃-60℃
|
|
Light sensitivity
|
70,000lux
|
|
Weight
|
4.7g
|
|
Communication interface
|
UART 115200
|
|
LED peak current
|
800ma
|
|
Serial port TTL voltage level
|
3.3V
|
|
Electromagnetic Compatibility(EMC)
|
EN 55032 Class B
|
Software
– Connect Grove-TF-Mini-LiDAR to D2 port
– Download the Demo code and copy the whole Seeed_Arduino_TFlidar file and paste it into your Arduino IDE library file.
Step 1. The Grove-TF Mini LiDAR is a hexadecimal output data. Each frame data is encoded with 9 bytes,including 1 distance data (Dist). Each distance data has corresponding signal strength information (Strength). The frame end is the data parity bit.
|
Byte
|
Data encoding interpretation
|
|
Byte1
|
0x59, frame header, all frames are the same
|
|
Byte2
|
0x59, frame header, all frames are the same
|
|
Byte3
|
Dist_L distance value is a low 8-bit.
|
|
Byte4
|
Dist_H distance value is a high 8-bit.
|
|
Byte5
|
Strength_L is a low 8-bit.
|
|
Byte6
|
Strength_H is a high 8-bit.
|
|
Byte7
|
Integration time.
|
|
Byte8
|
Reserved bytes.
|
|
Byte9
|
Checksum parity.
|
- Step 2. Copy the code into Arduino IDE and upload.
Click Here
the full code is mentiond into the upove link









Reviews
There are no reviews yet.